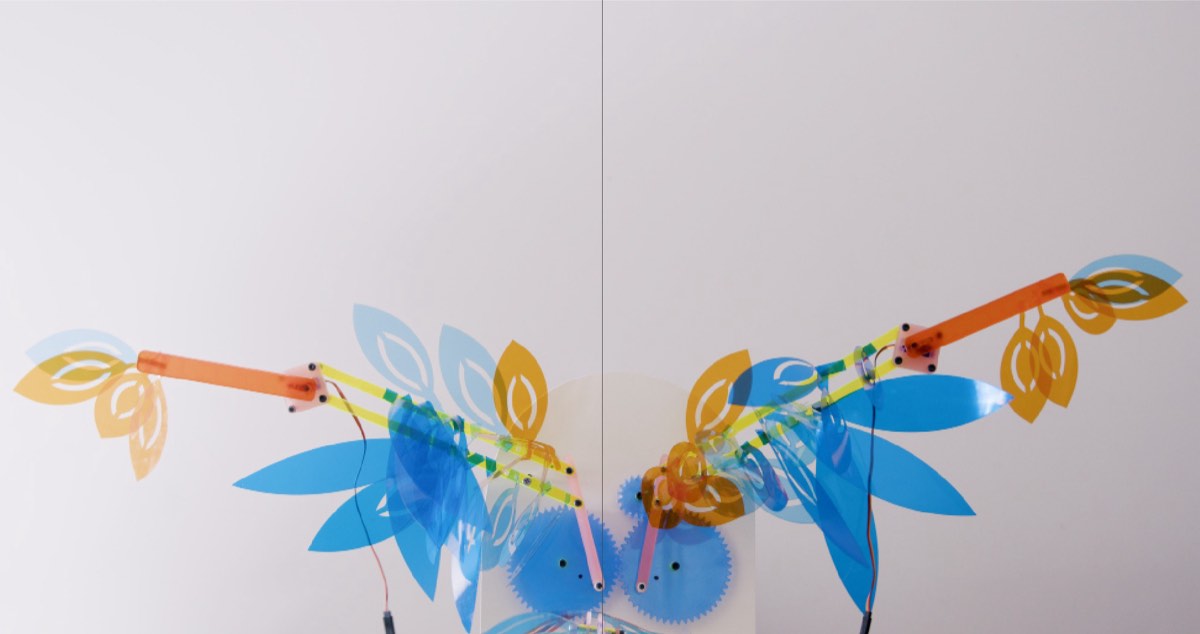
Mudras in Motion
Kinetic sculpture
- 4 mudras
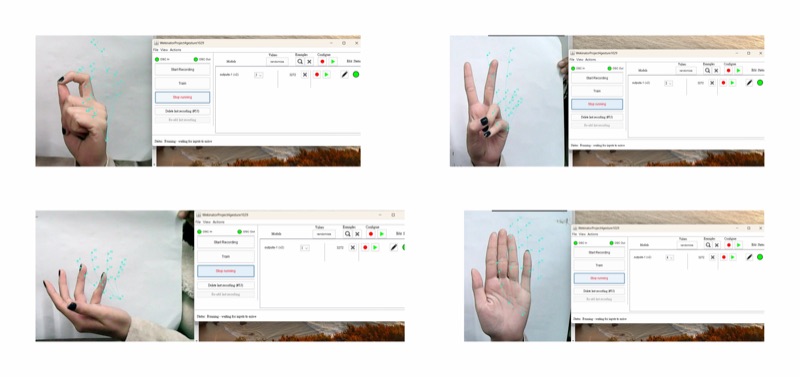
- read by a camera, sorted into four classes
- 3 servos, 1 stepper
- moving the sculpture
A sculpture that answers hand gestures.
01A language of hands
Bharatanatyam, a classical Indian dance, speaks through hand gestures called mudras. Each one carries a meaning. We chose four.
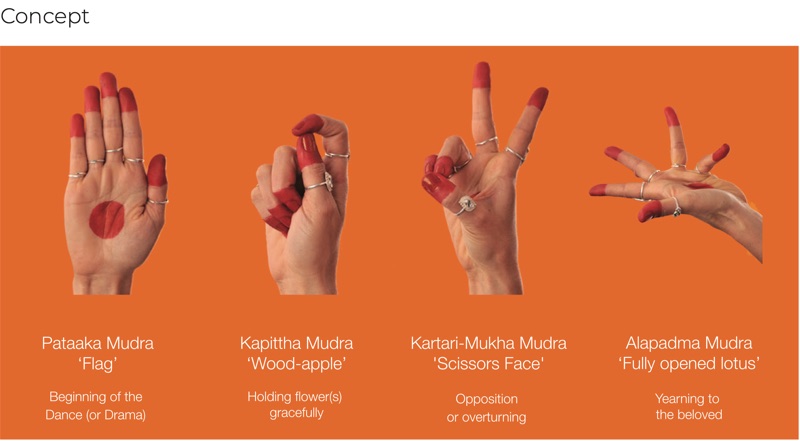
- Pataka, ‘flag’
- The beginning of the dance
- Kapittha, ‘wood-apple’
- Holding flowers gracefully
- Kartari-Mukha, ‘scissors face’
- Opposition, or overturning
- Alapadma, ‘fully opened lotus’
- Yearning for the beloved
02Reading the hand
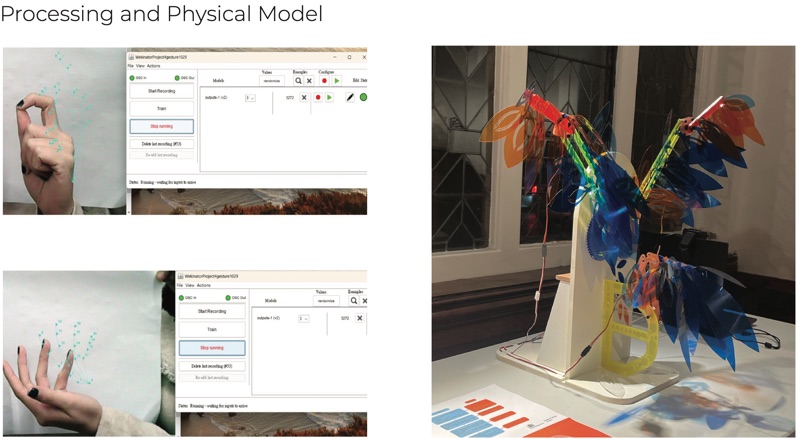
A webcam watches the dancer’s hand. Handpose OSC turns it into 63 numbers. Wekinator, trained on the four mudras, decides which one it is seeing.
03Moving the peacock
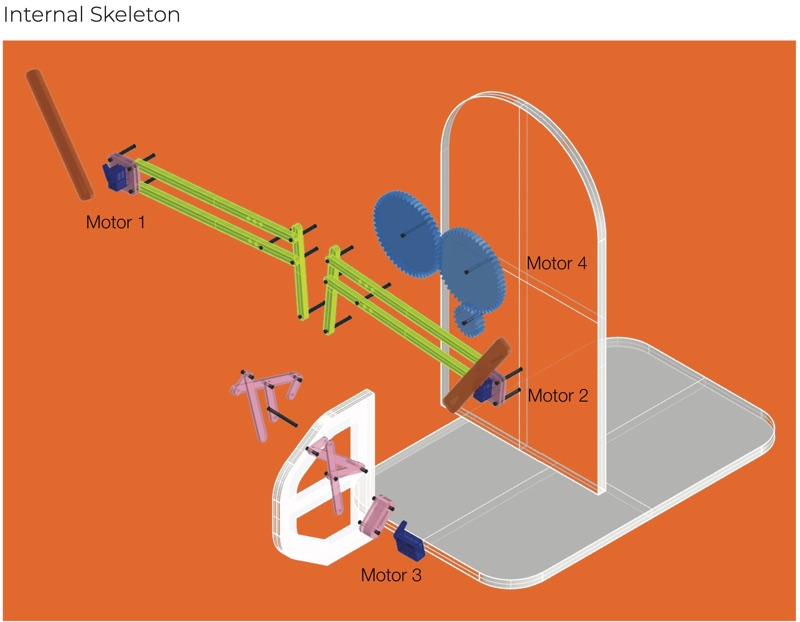
The sculpture takes its form from a peacock. An Arduino turns each mudra into its own movement of three servo motors and one stepper.
- 1 Track
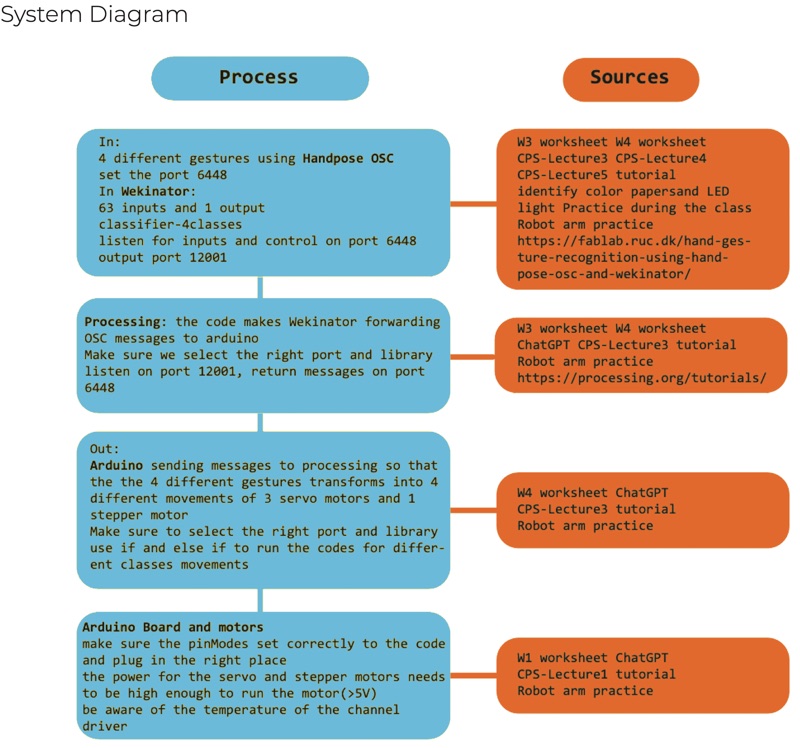
- Handpose OSC reads the hand from a webcam and sends 63 values to port 6448
- 2 Classify
- Wekinator, trained on the four mudras: 63 inputs, one output, four classes. It sends the result to port 12001
- 3 Forward
- A Processing sketch passes Wekinator’s OSC messages on to the Arduino
- 4 Move
- The Arduino turns each class into its own movement of three servo motors and one stepper motor
- Power
- The motors run on their own supply, above 5 volts. The driver’s temperature has to be watched
- Tools
- Rhino, Arduino, Handpose OSC, Wekinator, Processing
04Shown
Shown at Interplay, a kinetic art exhibition at the Royal Society of Sculptors, London. I designed the concept, wrote the Arduino code and built it with Hsintzu (Cindy), Harith and Sonia.